Tian Nian (粘天)
Algorithm Engineer Xspark AI (无界智航) B.Eng. Shenzhen University Creator control_your_robot
Bringing Robot Learning into the Real World
Algorithm Engineer at Xspark AI (无界智航), Shenzhen. B.Eng. in Software Engineering (Tencent Class) from Shenzhen University. Research on real-robot Embodied AI, covering robot control, data collection, and policy deployment on physical hardware. Creator of control_your_robot, core lead author of XPolicyLab (IROS 2026 Best Tool Paper Award), and contributor to RoboTwin 2.0 (ICML 2026).
 Email
 Scholar
 GitHub
 WeChat
Detailed Profile (详细个人介绍)
Hi! I am Tian Nian (Chinese name: 粘天), an Algorithm Engineer at Xspark AI (无界智航) in Shenzhen. I received my B.Eng. in Software Engineering (Tencent Class) from Shenzhen University in 2025, and was a research intern at Shanghai AI Laboratory from Mar. 2025 to Sep. 2025. My work focuses on real-robot Embodied AI: building the systems that connect robot hardware, teleoperation, data pipelines, and learned policies, so that research models can actually run on physical robots.
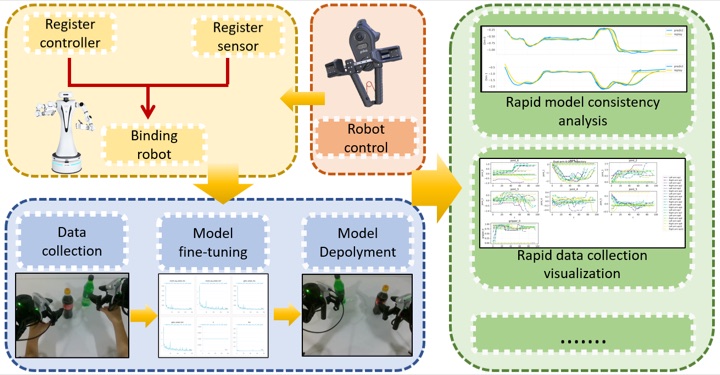
I created control_your_robot, an open-source pipeline covering robotic arm control, data collection, and VLA training and deployment. I am a core lead author of XPolicyLab, which received the Best Tool Paper Award at the IROS 2026 ScaleInfra Workshop, and a contributor to RoboTwin 2.0 (ICML 2026).
你好!我是粘天 (English name: Tian Nian),2025 年本科毕业于深圳大学软件工程(腾讯班), 曾于 2025.03—2025.09 在上海人工智能实验室实习,现任无界智航 (Xspark AI) 算法工程师,研究方向为具身智能真机方向,关注机器人控制、遥操作数据采集与策略的真机部署。 我是开源项目 control_your_robot 的作者, XPolicyLab 核心作者之一(IROS 2026 ScaleInfra Workshop 最佳工具论文奖), 并参与了 RoboTwin 2.0(ICML 2026)的研发。